Connecting movement and sensing.
Flex-sensor controlled robotic hand
An undergraduate team project exploring how a sensor glove can control a robotic hand, with pulse-monitoring integration as the application context.
Translate a gesture into movement
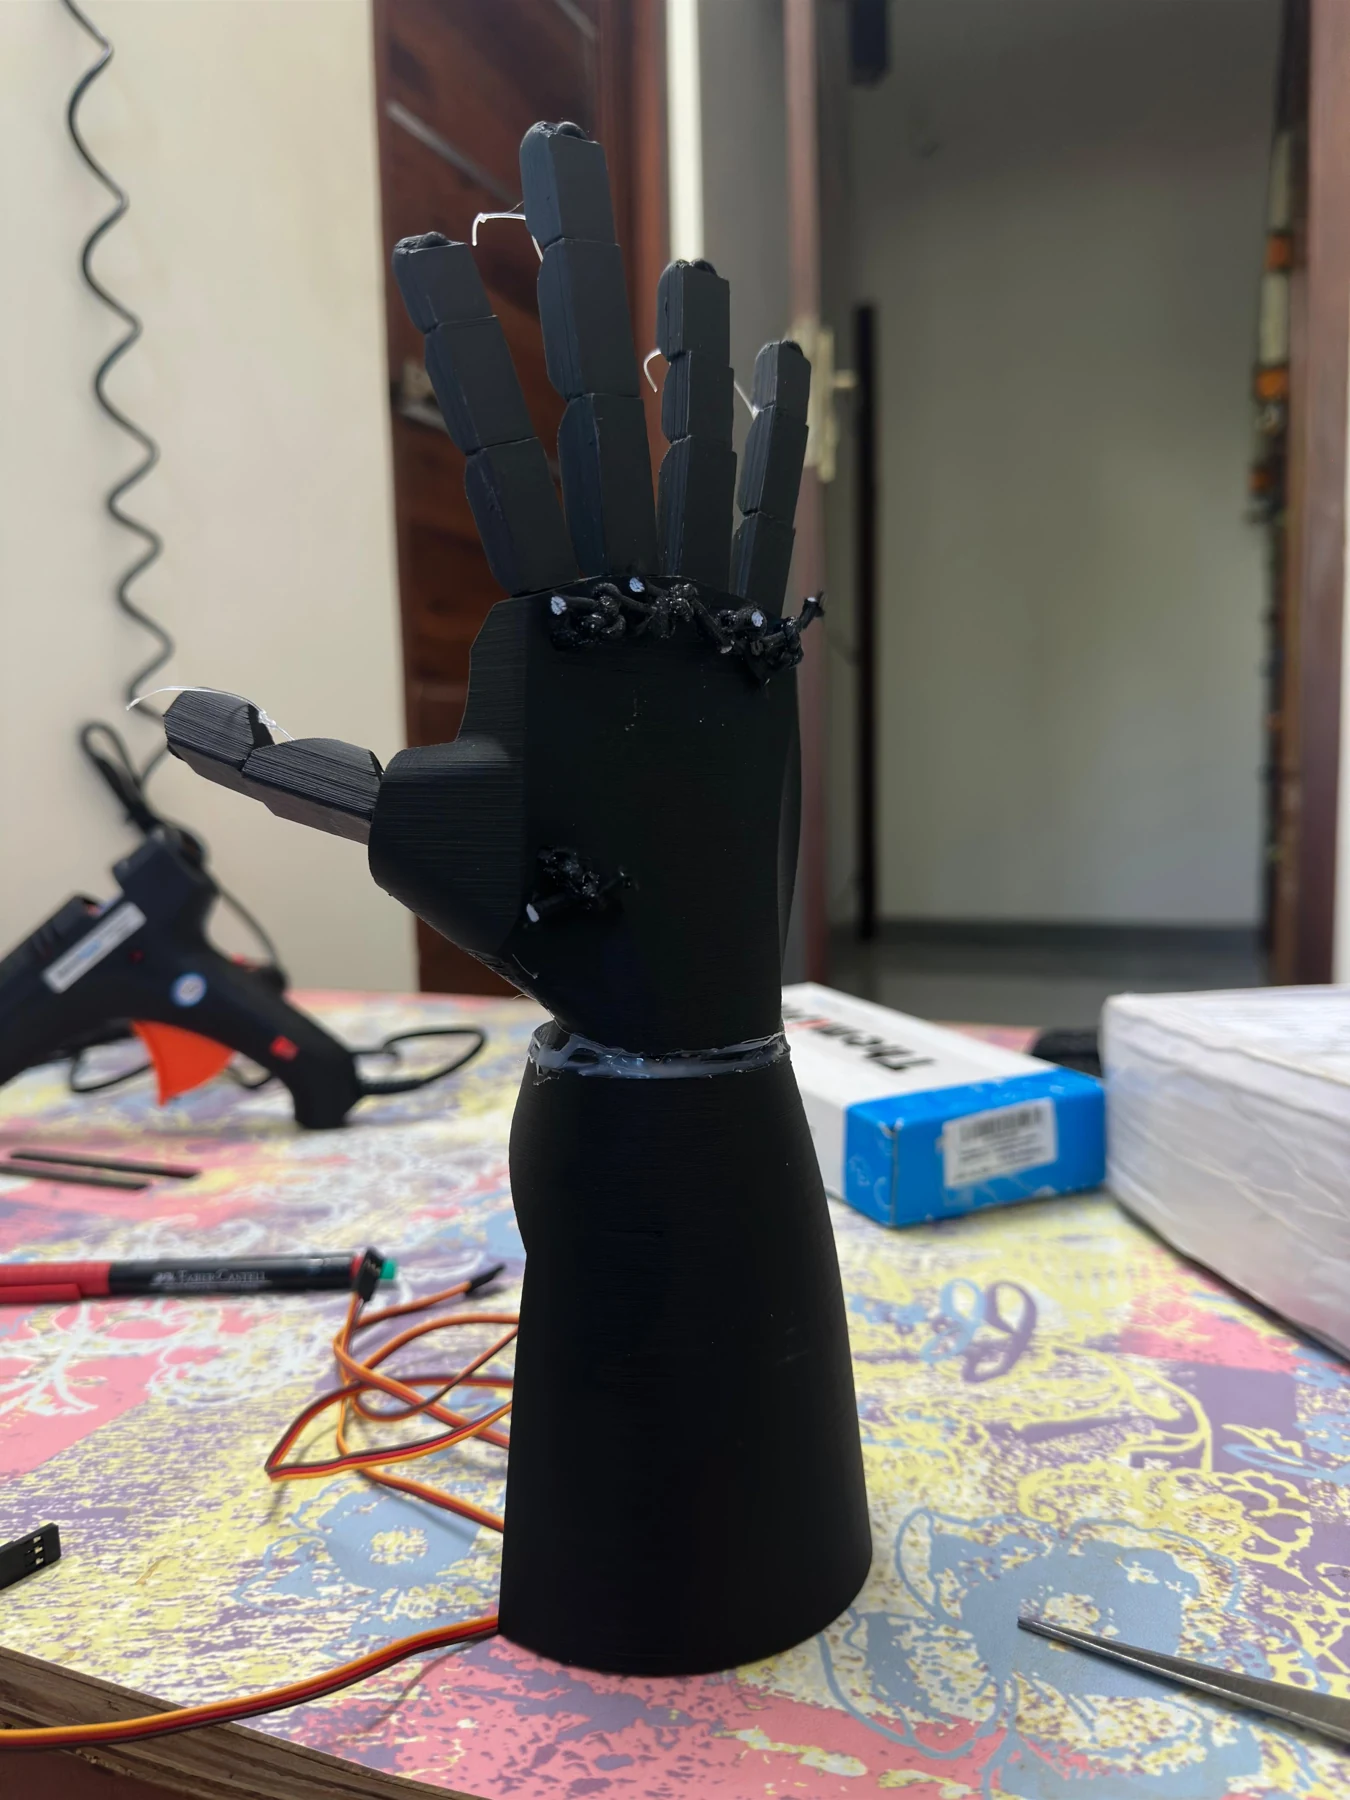
Flex sensors in the control glove provide inputs to an Arduino-based system. The project links those inputs to servo-driven finger movement, connecting sensing, control and a physical hand structure.
Bring the subsystems together
The prototype combines printed finger and forearm components, actuation and exposed control electronics. The photographs and bench recording document the assembly and movement during development. My work contributed to the mechanical arrangement, fabrication and integration.
The monitoring application
The report explores positioning sensors for non-invasive pulse monitoring. Sensor placement, stable contact and signal quality remain important development questions. I present this as an academic robotics demonstrator, without claiming clinical accuracy or completed medical validation.
What comes next
Improve repeatability and calibration, test movement limits and document the sensing results more systematically. Wireless integration and broader health-monitoring functions need clearer implementation and validation evidence before they can be treated as established capabilities.
1 / 3 · Select image to enlarge
The forearm opened to show actuation and electronic integration.
Bench demonstration
The original prototype recording shows finger movement and the exposed electronics during development. It is a mechanism demonstration, not a medical performance test.
Project evidence: March 2025 undergraduate report, presentation, original prototype photographs and bench recording. Completed as a team project with Kavi Bharathi.
Made. Tested. Made again.